SkyDrive: Learning to Drive in a New City from Aerial Traffic Monitoring
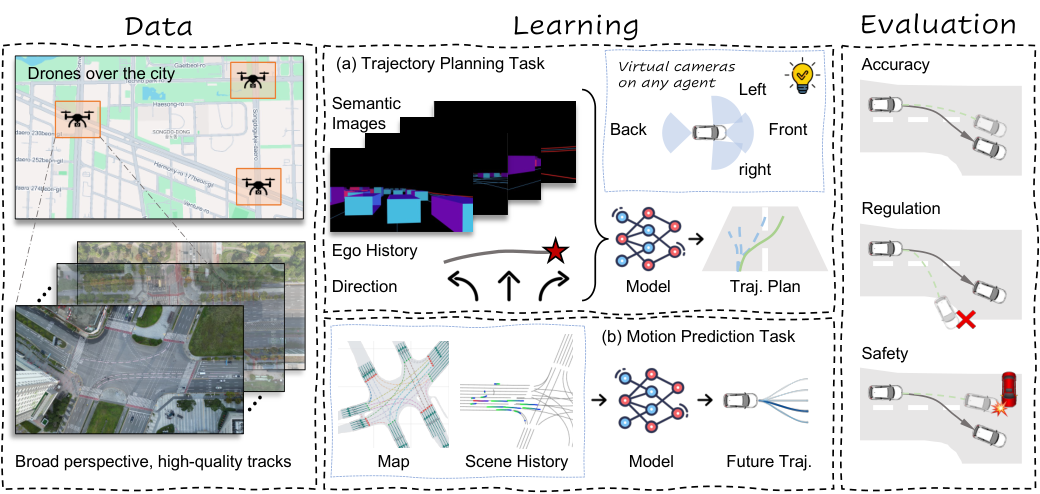
Uses aerial traffic observations to help autonomous driving models adapt to new cities.
arXiv preprint, 2026
I’m actively looking for industrial and academic opportunities in
Autonomous Driving and Embodied AI.
Hello, I am Weijiang Xiong (熊伟江), a Ph.D. candidate in Robotic Systems at EPFL (EDRS), advised by Prof. Nikolas Geroliminis and co-advised by Prof. Alexandre Alahi.
My research focuses on learning from real-world traffic, with the goal of developing autonomous systems that accounts for uncertainty and adapts to changing environments. I develop probabilistic models of traffic dynamics and study how aerial traffic observations can support autonomous driving. My recent work turns aerial urban traffic monitoring into driving scenarios and supervision for adapting driving models to new cities. I am also exploring reinforcement learning for active urban sensing.
My earlier work in visual perception, Bayesian machine learning, and domain adaptation shaped my interest in the reliability of learned systems. During the journey, I had the pleasure to work with Dr. Lorenzo Bertoni, Dr. Taylor Mordan and Dr. Markus Heinonen. My longer vision is to learn autonomous driving and its environment, i.e., the transportation system, by connecting traffic observation, behavior learning, and adaptive decision-making.
Research interests
My work spans probabilistic traffic forecasting, learning from aerial observations, and understanding road users’ behavior.
Uses aerial traffic observations to help autonomous driving models adapt to new cities.
arXiv preprint, 2026
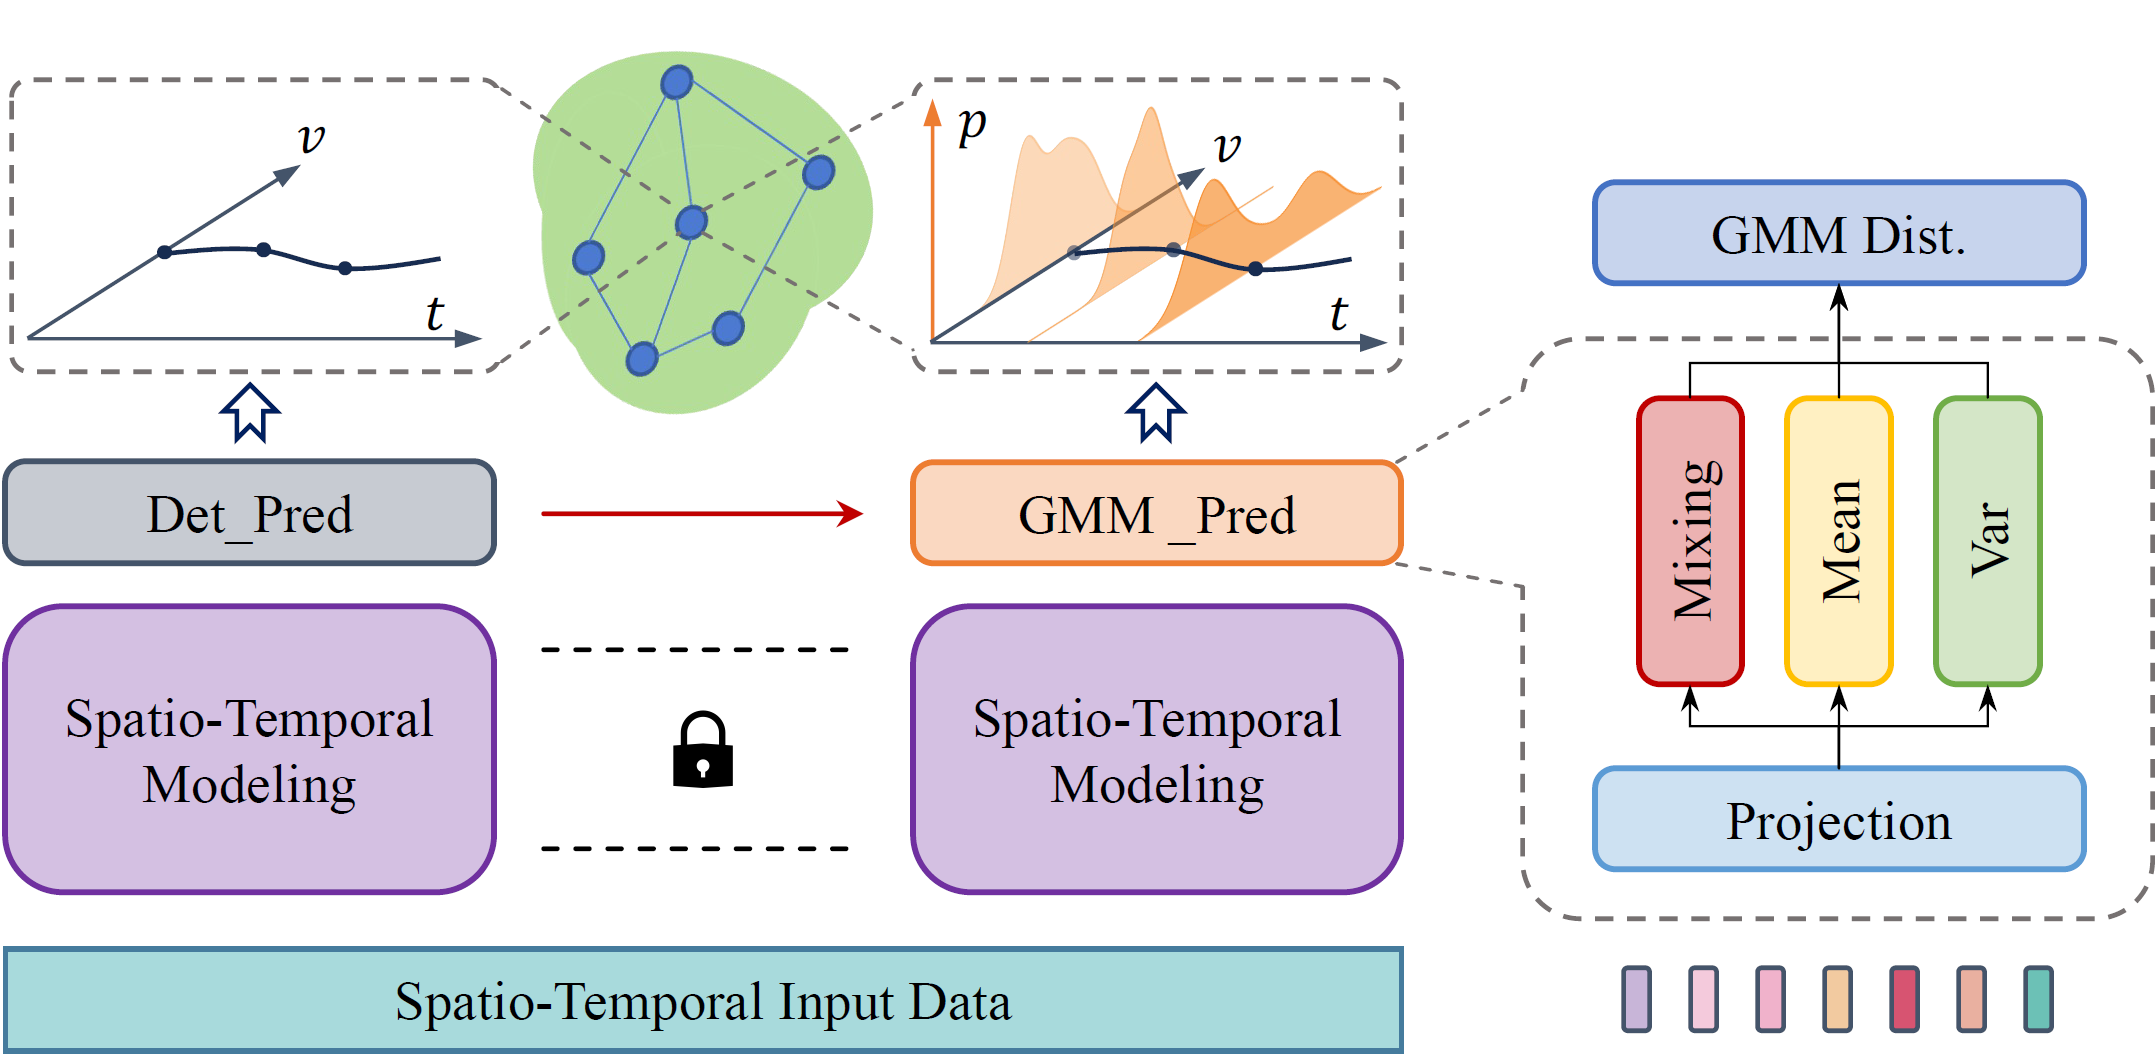
Turns traffic forecasting networks into probabilistic predictors with a Gaussian Mixture Model output layer, capturing multiple possible future traffic states and their uncertainty.
Transportation Research Part C: Emerging Technologies, 2026
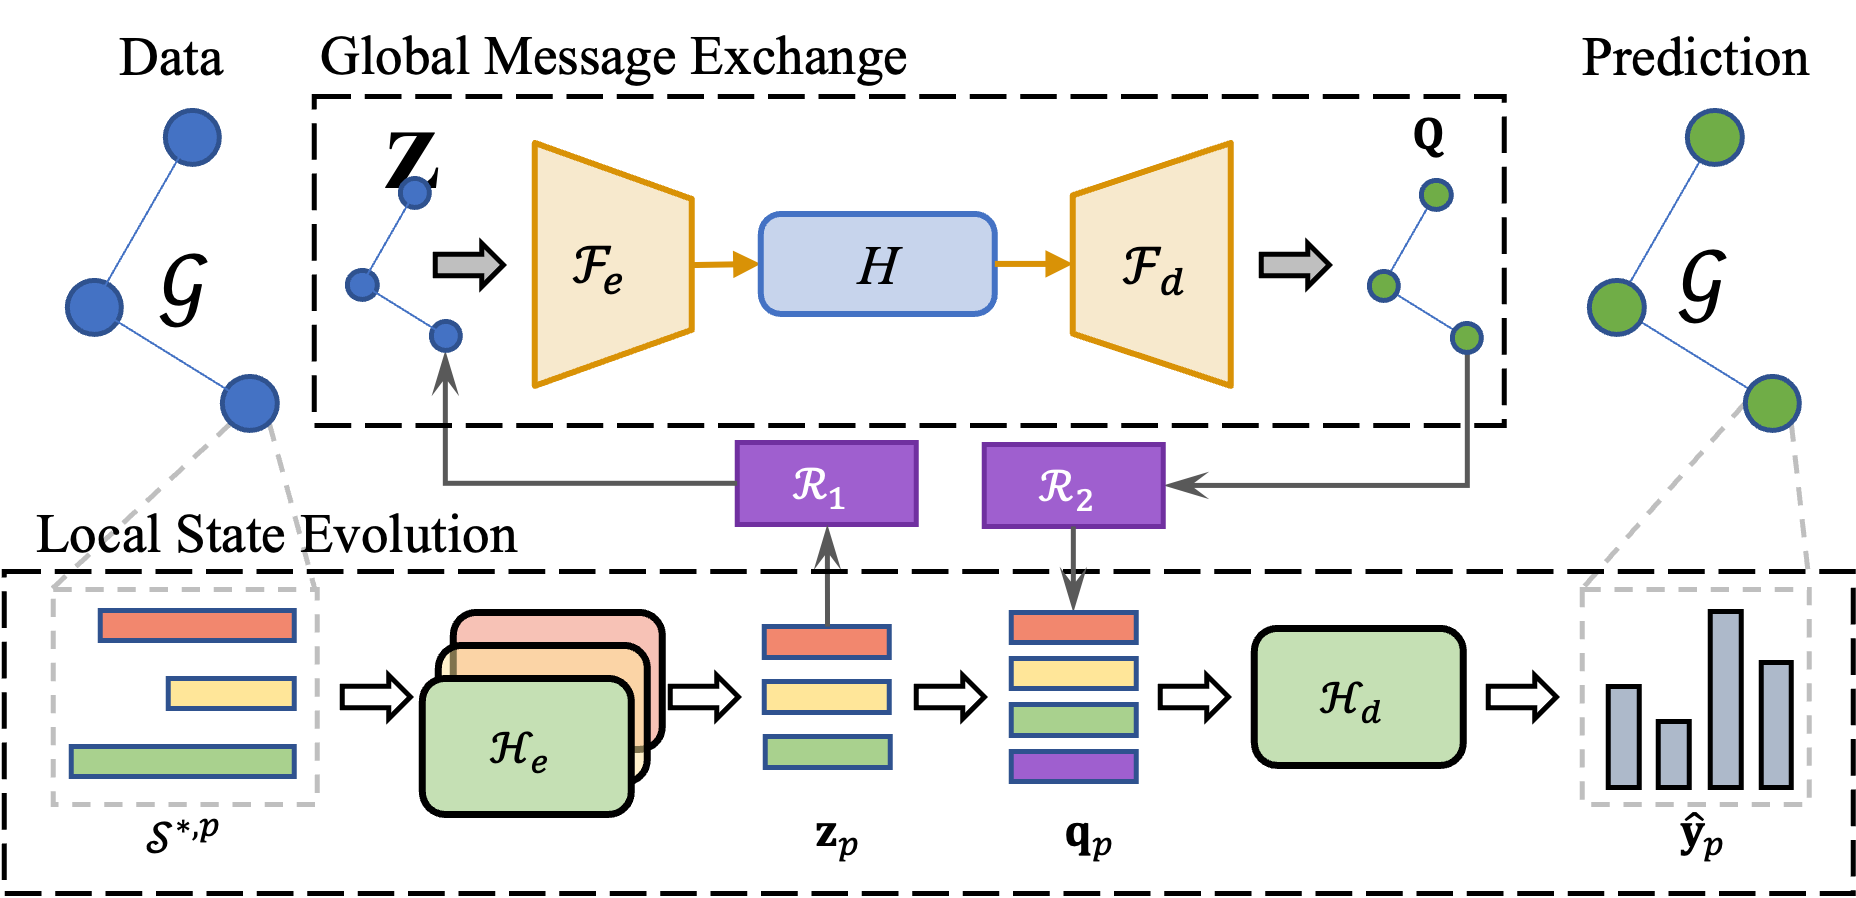
Combines loop detector measurements and drone observations through a hierarchical neural network for urban traffic forecasting, accompanied by a multi-source dataset built from vehicle trajectories.
IEEE Transactions on Intelligent Transportation Systems, 2025
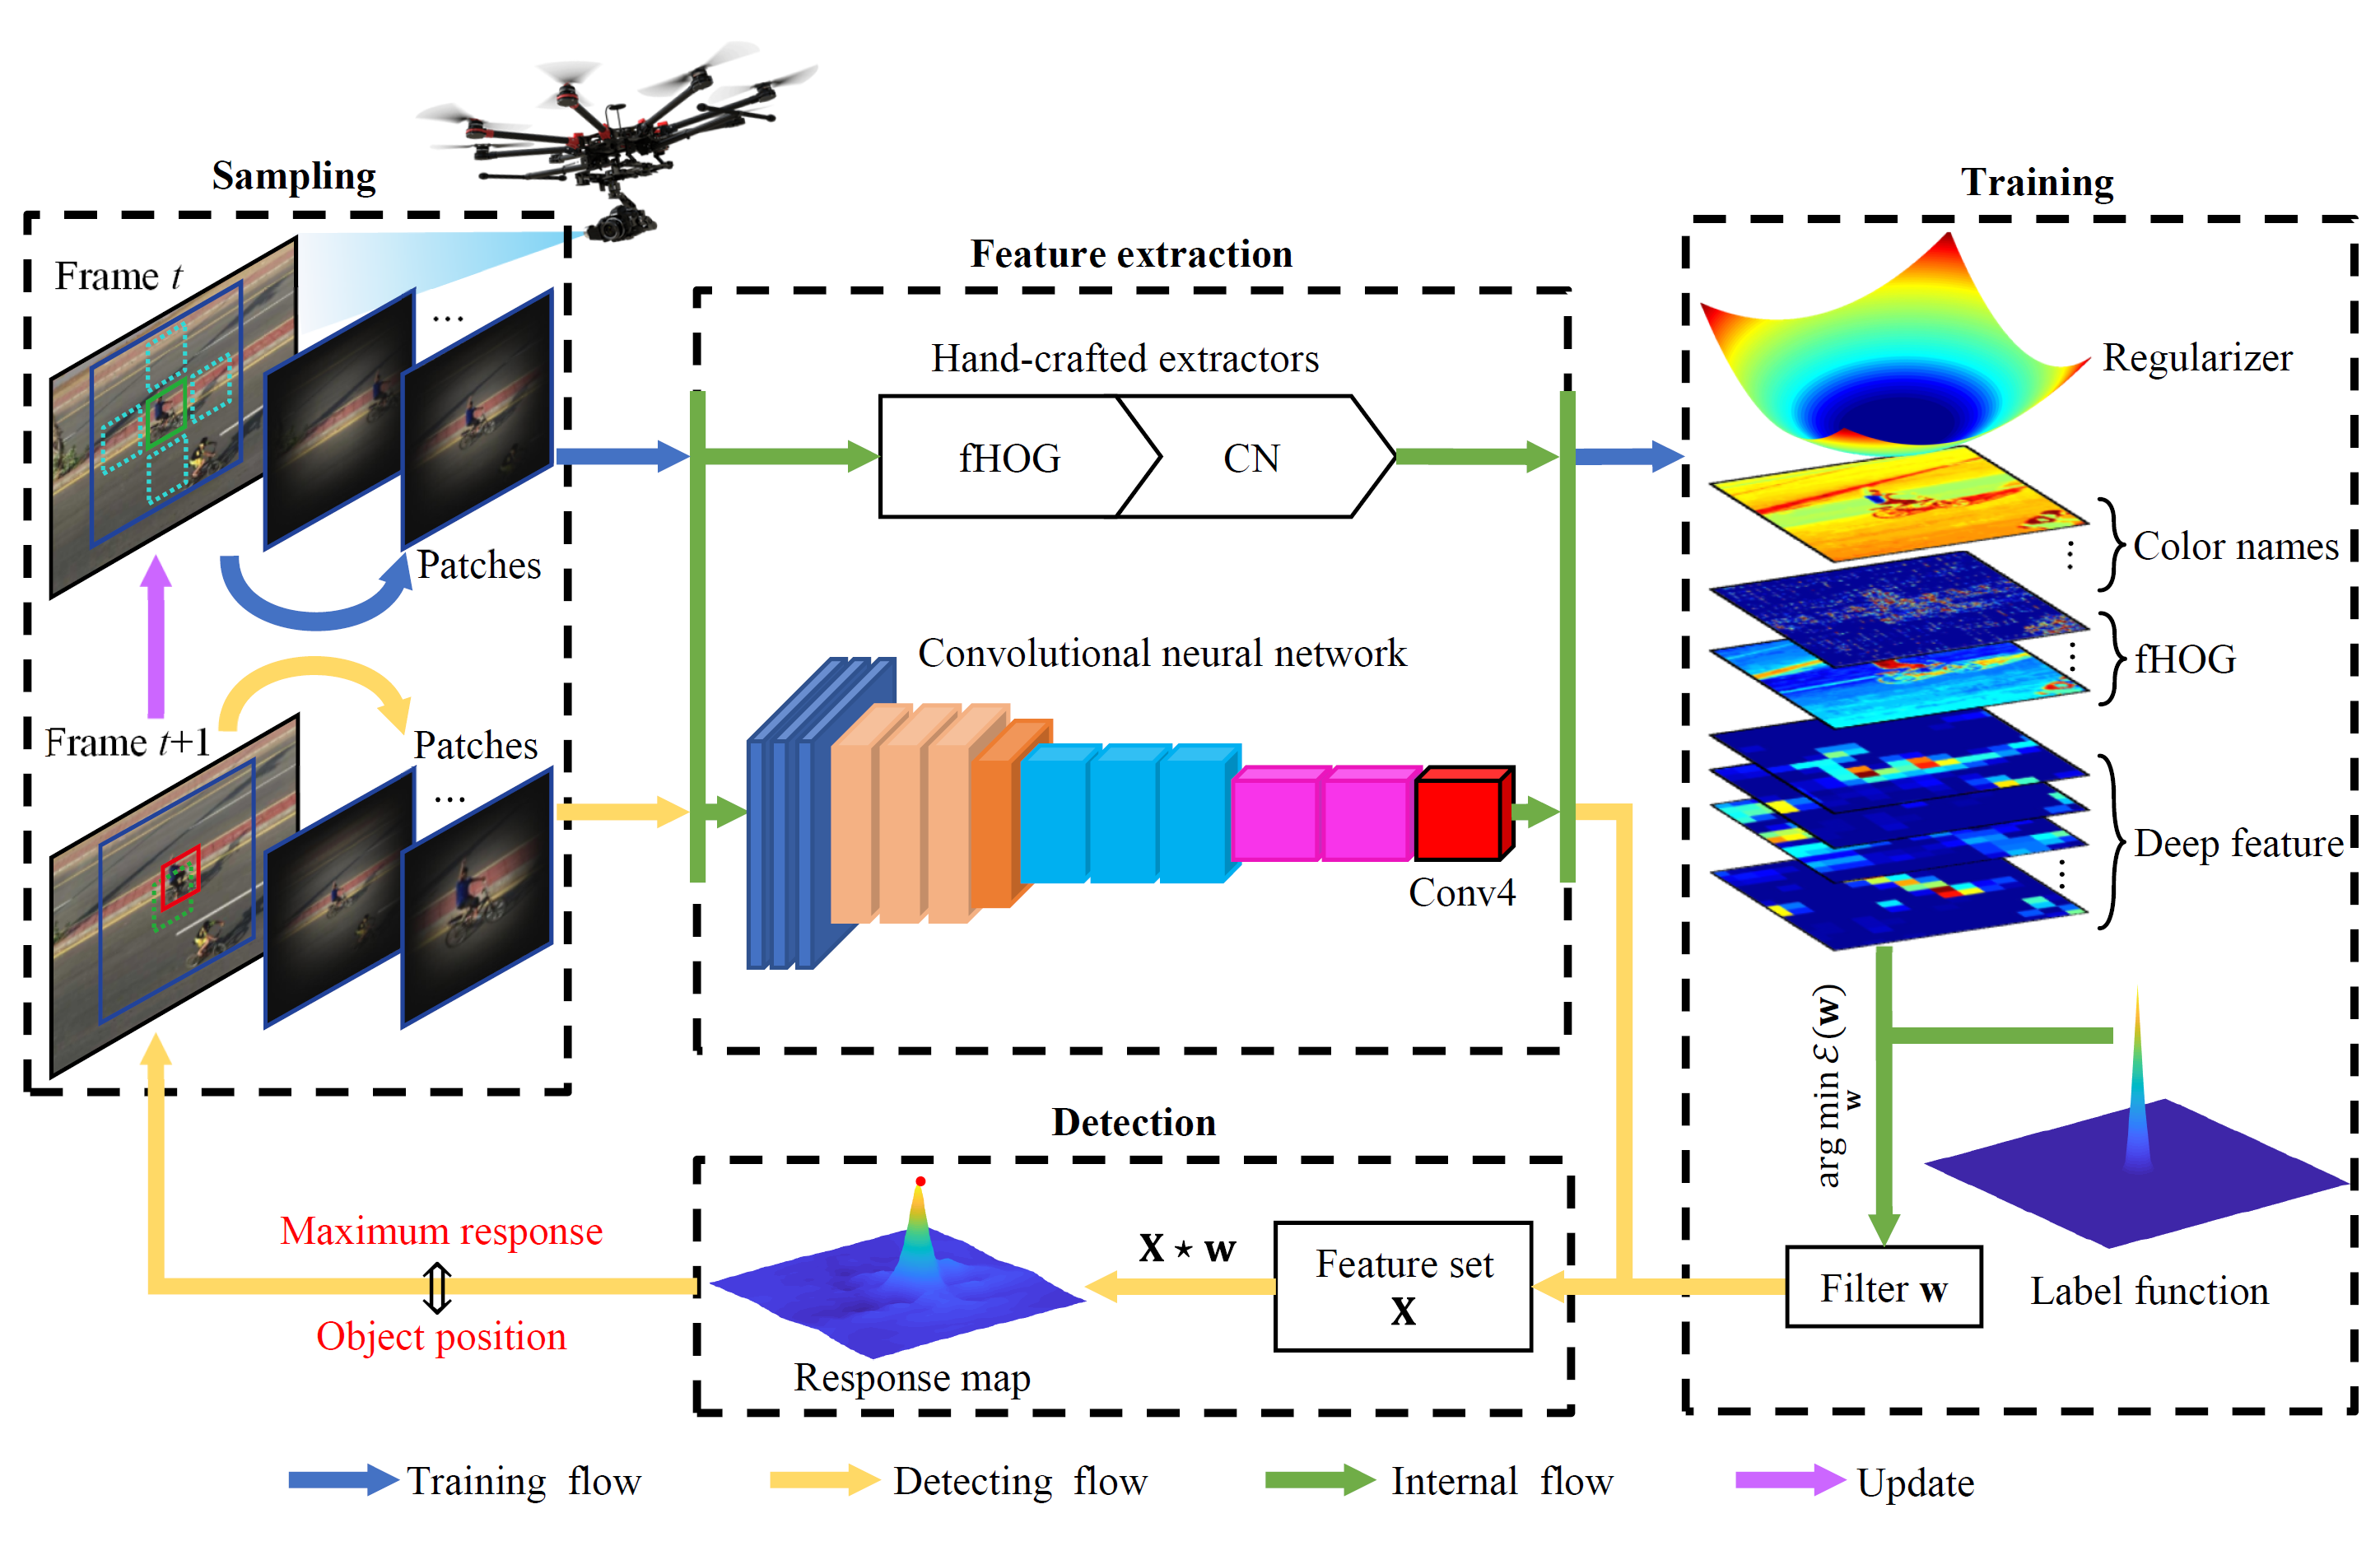
Uses surrounding context and selective spatial regularization for visual object tracking from unmanned aerial vehicles.
Signal Processing, 2020
GMM Traffic paper accepted by Transportation Research Part C.
HiMSNet paper accepted by IEEE T-ITS.
SASR tracker paper accepted by Signal Processing.
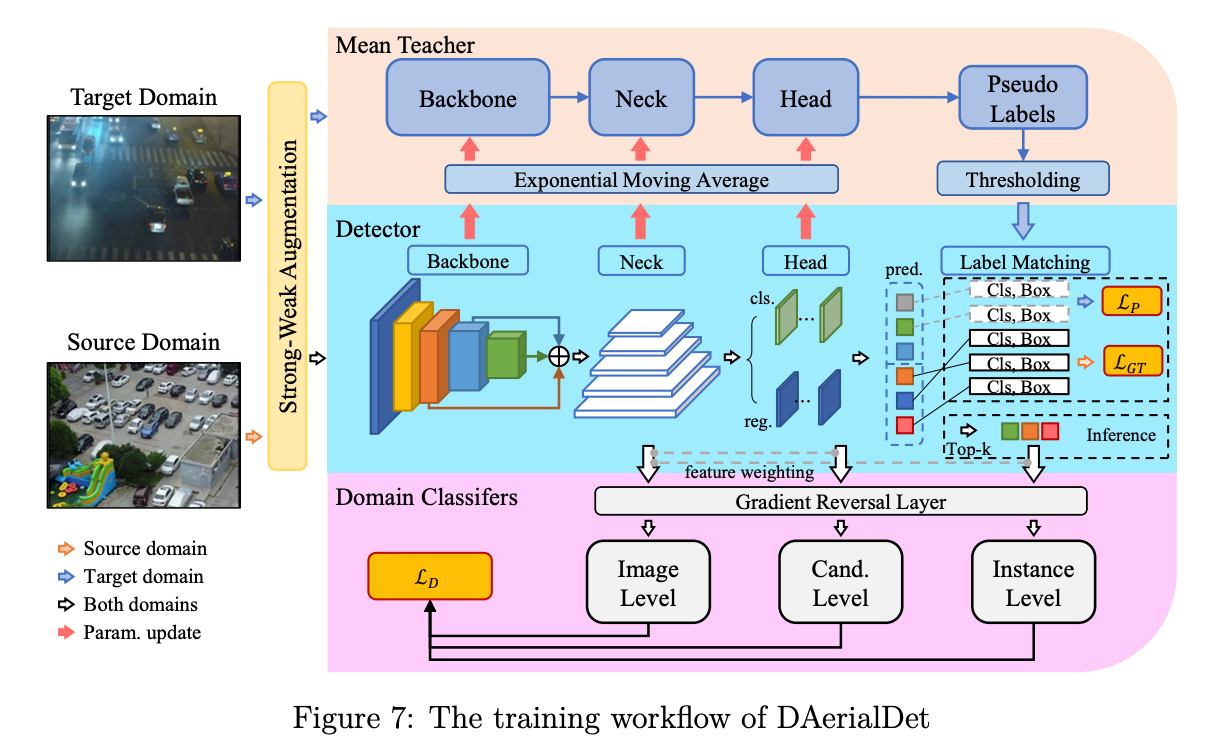
Nokia · Master’s thesis
Domain-adaptive aerial object detection using feature distribution alignment and knowledge distillation.
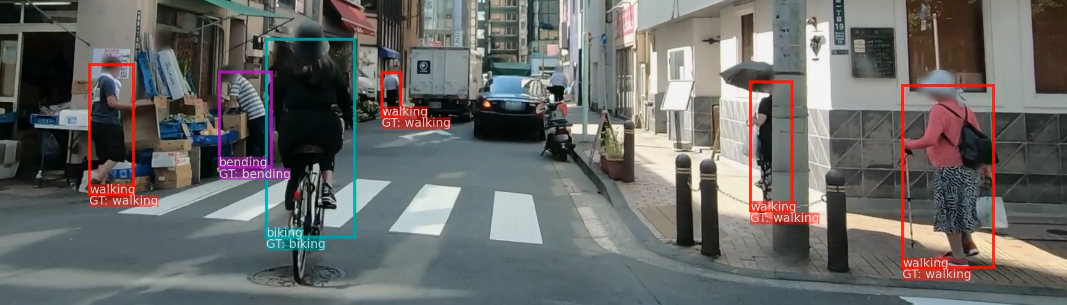
Action recognition
Lightweight recognition of common road user actions from human body poses.
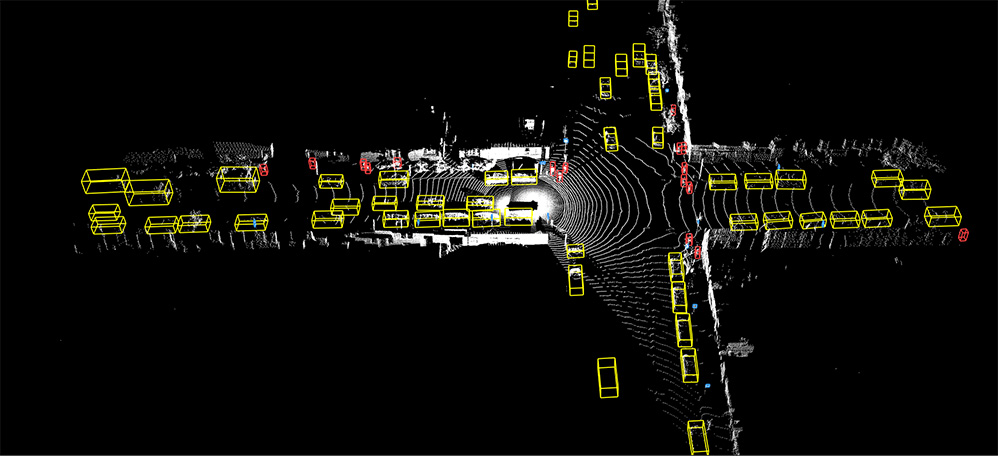
Hesai Tech · Research internship
Voxel-based 3D vehicle detection for autonomous driving using the Waymo Open Dataset.
Dec 2022 — Present
Sep 2020 — Nov 2022
Sep 2015 — Jul 2020
Feb 2022 — Nov 2022
Master’s Thesis Intern
Jun 2021 — Aug 2022
Summer Intern · Aalto University
Jul 2020 — Aug 2020
Research Intern · Algorithm Group · Shanghai
Contact
Weijiang Xiong · EPFL · Lausanne, Switzerland